You want the good news first, or the bad news?
The good news is, we set another record: 190m.
The bad news is ... huh, there is no bad news. It's all good news.
Jeff was the first to announce the results. He got up way early (or stayed up way late) and sent out a triumphant email at 5:45. I was up to see it at about 6. And neither of us is exactly a morning person.
To congratulate us, Jeff Favretto -- our mission manager that sol and this -- brings in doughnuts, with a congratulations message hand-written in black marker on the top of the pink box. Charles has the honor of announcing the record as the Spirit SOWG meeting is breaking up to make room for Opportunity, and there is much rejoicing. "So that's where the dust devils are coming from," one of the scientists jokes.
It couldn't be a more appropriate sol for the quote that illustrates our rear-looking track image in the Long-Term Planning report, which (as usual) leads off our SOWG meeting. It's a Dakota proverb: "We will be known by the tracks we leave."
The drive should have left us just next to a crater which, yesterday, Ray dubbed "James Caird Crater." (Caird, a whaler, was an important part of Shackleton's expedition. Caird was a Scotsman, which makes him all right by me.) The problem is, we can't see this crater in the images we have. The minimal downlink only gave us forward-looking images, and the crater would be to the west or southwest of us. That crater was our only landmark, meaning that, in a sense, we have no idea where we are.
Perhaps I shouldn't be so dramatic: we have some idea of where we are. Probably a pretty good idea. We'd just like to be able to prove it.
We took NCAM images after the drive; when they make it to the ground this weekend, we should be able to see James Caird Crater in them. Or so we hope. But it seems a shame to be sitting just a few meters from what looks in the orbital imagery like a pretty darn nifty crater, and not get some good images of it. Plus, solid images with good range data would help localize us really well. So, in the back row, Justin Maki and I start scheming. But to little avail: in the end, we fail to talk the science team into spending the bits on it. They might catch it in a PCAM panorama they're taking before we drive on, but the panorama is probably aimed too high (this one needs to be, for science reasons). So we might never see the crater at all.
Well, that's a shame. But the upside is, if indeed we don't see it, it will be because we drove away. Really, really far away. In order to help avoid a repeat of Spirit's squeaky-wheel problem, we're letting the rover rest Friday (today) and Sunday. But Saturday, we're driving with a vengeance. We would have driven a little farther than 190m on the previous drive, but autonav found some obstacles to avoid early on and lost a little time edging around them. Assuming that doesn't happen again this weekend, we'll break 200m this time for sure.
Once the drive sequence is in the bag, Jeff and I take a little time to brainstorm ways to drive even farther on future sols. We don't see a lot to optimize in the current approach -- all the parameters are cranked up as far as is safe, and the general structure of the drive sequences is about as good as it can get. We blind-drive as far as we safely can given the imagery we've got -- lately, this has been about 100m -- and then we switch to the much slower autonav. So the most obvious way to squeeze more time out of a drive is to extend the length of the blind segment.
But we can't, because we're driving as far as our stereo imaging allows. Unless -- "Hey," I say, "what if we did long-baseline stereo? Take an image-pair in the drive direction, drive laterally a few meters, and take another image-pair." I think this is a great idea, but it doesn't seem to set Jeff afire. Turns out they've done this before on the plains, and it didn't seem to improve the data all that much.
Oh, foo. I thought I was being all creative.
[Next post: sol 433 (Opportunity sol 412), March 22.]
2010-03-19


2010-03-18
Opportunity Sol 408 (Spirit Sol 429)
The regular science team has returned from their conference, so Charles is out as SOWG chair (after a damn honorable term of service) and Ray is back.
And thisol is the first sol we're going to seriously shoot for 200m. Apparently, Steve Squyres has been privately campaigning for this. Another person who likes the idea has a pithy reason: "Just to stick it in MSL's eye."
So they give us a heck of a long time to drive: an hour of blind driving followed by three and a half hours of autonav. In the best possible case, this would give us time to drive 235m or so, with 210m being a more likely outcome.
But this judgment is reduced on appeal, as it were. The PCAM team wants to do some damn imaging or something, and then other stuff comes up, and by the time it all settles out, our 3.5 hours of autonav is down to 2.5.
So we won't break 200m thisol, not even by extending the blind drive. But we might come close. And that'll still be pretty darn good.
2010-03-17
Opportunity Sol 407 (Spirit Sol 428)
I have mixed feelings about the result of yestersol's drive. Frank and Brian were given a record-long amount of time to drive -- four hours and fifteen minutes -- and they put it to good use. The new one-sol record is 183m. Great news for the project, but as the now-eclipsed record holder, I can't help feeling a little sad.
And I won't get to regain the title today; they can't spare enough time to drive. We might get 150m or so, though, which used to seem really good but now seems hardly worth spitting on. Since we can't beat the record anyway, I generously accede when they ask for a couple of unusual procedures -- one where we'll stop in the middle of the autonav segment and do some mid-drive imaging (a first, I think, so at least I get to invent something); and another where we have a second, comm-turn-only, drive sequence. Maybe agreeing to this will make me feel like less of a bastard if I decide to refuse them on some sol where we could set the record.
Aw, who am I kidding? I'd never do that.
Charles Budney is the SOWG chair this week. Normally he's a Mini-TES guy, but he's temporarily filling in for a number of absent SOWG-chair types, who are off at some conference. He's been only too happy to let the rover drivers drive, which, as I tell him, is going to make him one popular SOWG chair.
"Just as well," he says, "since it looks like the Mini-TES is dead." This has been the subject of investigation for the last couple of weeks or so. The normally reliable instrument suddenly started returning errors instead of data. The more stuff they've tried, the more their hope has faded. I know Charles in particular has a pessimistic streak, and there's been no formal announcement yet, so I'm still holding out some hope myself (read: "I am still in denial"). The loss of this instrument would be bad, since it helps us determine chemical composition at a distance -- a very powerful tool in our toolkit. I guess we'll see.
Maybe rover death is the somber theme of the day. Downstairs in the sequencing room, Brian Cooper and Justin Maki start talking about what it will be like when one of the rovers dies. "They'll start making fault trees" -- "Pulling people back from other projects" -- "They'll keep trying for about two weeks" -- "Yeah, two weeks is about right, two weeks in denial" -- "They'll think maybe they saw a glitchy signal" -- "It's sad, but you learn a lot about radio science when something like that happens."
"Chris Salvo was saying it's gotten to be like the rovers are right in our back yards," Justin says. "And he's right, it is. But at any minute, they could be a hundred million miles away again. It could happen like that."
What a comforting thought.
In happier news, the dust devil that recently cleaned off Spirit's solar panels seems to have removed the dirt clod from the magnets as well. That's the dirt clod that's been there since the MB picked up a chunk and wiped it off on the magnets, way back during conjunction. I haven't seen the MB lately, but last I saw, a lot of the dirt that had stuck to it was gone as well.
"I need crater names that start with a 'V,'" Charles announces. "These are supposed to be ships of exploration." He doesn't get enough suggestions that start with "V," so he relaxes that requirement and suggestions start flowing faster. Jay Torres suggests "NCC-1701." Cooper suggests "The Minnow," and that one is definitely going to get used.
"We should use that name for one of the craters where we stop and IDD," I say. "Because the target names are so obvious -- Gilligan, the Skipper, ...."
"And if we don't," Charles says, "The Minnow would be lost."
That one almost physically hurt. What did I ever do to him?
2010-03-12
Opportunity Sol 403 (Spirit Sol 423)
Yesterday we planned sols 402 and 403 (which executes today); today we plan the weekend sols, 404 and 405. Khaled could use the experience, so I have him do the bulk of the RP-1 work today.
Which is easy, since he already did most of it yesterday. I spend most of the day struggling with a tricky m4 problem. Don't get me started. But he calls me over to help out with something weird: the INCONs file ("INCONs" is short for "initial conditions" -- it specifies the rover's last known position, which is how it will start the day) shows the rover with the APXS in the wrong position. Instead of being directly on the target, the instrument is laterally offset by about 3.4cm.
On comparing the numbers from that file to the numbers we expected, we find it's offset by the right amount to be an MI poker offset. This term takes some explanation. When we're trying to get good MI images of a rock surface, often we first touch it with the MI's poker, a small, thin, steel rod affixed near the MI's lens. When it senses contact, we back off a known amount, and we can trust that the resulting images will be in good focus.
But the poker doesn't project directly out of the lens, obviously, which leads to a minor problem: when the rock surface is uneven, the poker might contact a position higher or lower than the area we're trying to image. This could lead to out-of-focus images or, in the worst case, we could smash the MI lens while the poker felt nothing.
So in these cases, we do the poker touch differently. First, we slide the instrument over by a known lateral offset, putting the poker where the lens was. Then we touch and retract. Then we slide back, putting the lens directly over the position the poker touched.
And the offset we're seeing in the APXS placement has just the right magnitude to have been introduced by this procedure -- if, for instance, we slid over but didn't slide back. Nothing else we normally do moves the IDD in this exact way, so it has to be some kind of poker-slide problem. And the scientists aren't going to like it: it would mean that some if not all of our instrument readings have been at the wrong location. Basically, we might have wasted one or more entire sols, and we'll have to do them over.
But there's still a puzzle. While the offset has exactly the right magnitude to have been caused by this error, it's not in the direction we would have used in this case. And when Khaled and I look carefully through all the sequences that have executed since the last known-good placement, we can't find the problem in any of them. So we look again, and we still can't find it.
But it has to be that. And I'm quite prepared to believe it is, since we very nearly made exactly this mistake in the last IDD sequence I built; I caught it in time (because I noticed the simulation looked wrong), but we know the problem could bite us.
So it has to be an MI poker-slide problem. But it isn't. What the hell is going on?
Grasping at straws, we reload the INCONs file -- and suddenly the IDD snaps into the right position. Turns out there was an error in the original file, and the Mobility/IDD team corrected it, probably right after we loaded the erroneous version. Everything's fine. We've just wasted half an hour chasing a ghost.
Well, I'll say this: it sure as hell could have been worse.
[Next post: sol 428 (Opportunity sol 407), March 17.]
2010-03-11
Opportunity Sol 401 (Spirit Sol 422)
Four hundred sols, baby. That's what I'm talking about!
The drive to Vostok went damn near perfectly, which apparently means the curse is lifted. As we suspected from the previous images, Vostok is large but very shallow, kind of like Shaquille O'Neal. (Just kidding, Shaq!) Over the millennia, the crater has almost completely filled with dust and soil. Now, only a broad ring of broken stone, like a circular garden path tens of meters across, shows where a meteor struck once, untold ages ago. At least some of Mars's ancient wounds have healed.
Frank and Brian spent yesterday starting on some IDDing of outcrop that ended up right under us, just as we were hoping. We'll likely continue that work over the next several days.
That's what we're doing today, for example. We're planning two sols today and another two tomorrow, so that we won't have to work Saturday. I think this is a great approach (heck, I advocated it myself yesterday), but it so happens that the two most complex sols out of those four are the two we're planning today. Well, if the work weren't difficult, they could find someone cheaper than I to do it.
What makes the sols complex is that we're RATting on both of them. I haven't done this for a while and had almost forgotten how much there is to it. RATting is usually part of a broad campaign that involves complex placements with all of the instruments, and this time's no exception, so the sol keeps me hopping.
It does give me a chance to play with a new flight software feature that tests directly for RAT contact with the terrain. It's a vast improvement over the old way we had to do it, which required deliberately generating a fault and some tricky logic to determine the cause of the fault and conditionally clear it. So this is good.
But the large workload and short timescale (it would be a tight sol even if we were planning only one) has a predictable effect: I revert to get-the-fuck-out-of-my-way mode, in which I trade politeness for efficiency. (Ahem.) I've been trying not to do this, but old habits die hard, and I have to admit this one is damned effective. Andy's already worried that he's been scheduling me for too many shifts, so he asks later, "Are you okay? You seemed a little testy earlier." I hope my reassurance suffices, because I want him to schedule me more! More! MORE!
Uh, anyway. What with all the work, I miss my chance to appear in an IMAX movie[1] they're filming downstairs; among other things, they're attempting to re-create the landing and egress. But it's probably just as well: the world doesn't need to see my face on a screen the size of a city block. On a screen the size of a thimble, maybe that's something the world needs to see. But a screen the size of a city block, forget about it.
Tomorrow would be simpler than today no matter what, but once today's in the bag (with an hour to spare, mind you; maybe I really don't need to be such a jackass), Khaled and I get to work on tomorrow's sequences. Khaled hasn't built IDD sequences from scratch yet, and doing it with no time pressure is the right way to do it. He's come along really well, and is turning into a fine rover planner.
But he can't have any of my shifts. More. More! MORE!
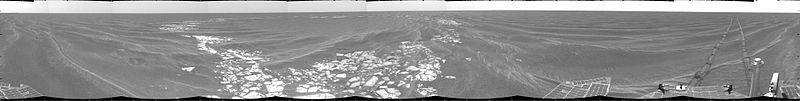
Courtesy NASA/JPL-Caltech; mosaic image hosted at Wikipedia. This is the entire 360-degree NAVCAM panorama, including (centrally) the broad ring of outcrop outlining what's left of Vostok Crater.
Footnotes:
[1] This, of course, was Roving Mars.
The drive to Vostok went damn near perfectly, which apparently means the curse is lifted. As we suspected from the previous images, Vostok is large but very shallow, kind of like Shaquille O'Neal. (Just kidding, Shaq!) Over the millennia, the crater has almost completely filled with dust and soil. Now, only a broad ring of broken stone, like a circular garden path tens of meters across, shows where a meteor struck once, untold ages ago. At least some of Mars's ancient wounds have healed.
Frank and Brian spent yesterday starting on some IDDing of outcrop that ended up right under us, just as we were hoping. We'll likely continue that work over the next several days.
That's what we're doing today, for example. We're planning two sols today and another two tomorrow, so that we won't have to work Saturday. I think this is a great approach (heck, I advocated it myself yesterday), but it so happens that the two most complex sols out of those four are the two we're planning today. Well, if the work weren't difficult, they could find someone cheaper than I to do it.
What makes the sols complex is that we're RATting on both of them. I haven't done this for a while and had almost forgotten how much there is to it. RATting is usually part of a broad campaign that involves complex placements with all of the instruments, and this time's no exception, so the sol keeps me hopping.
It does give me a chance to play with a new flight software feature that tests directly for RAT contact with the terrain. It's a vast improvement over the old way we had to do it, which required deliberately generating a fault and some tricky logic to determine the cause of the fault and conditionally clear it. So this is good.
But the large workload and short timescale (it would be a tight sol even if we were planning only one) has a predictable effect: I revert to get-the-fuck-out-of-my-way mode, in which I trade politeness for efficiency. (Ahem.) I've been trying not to do this, but old habits die hard, and I have to admit this one is damned effective. Andy's already worried that he's been scheduling me for too many shifts, so he asks later, "Are you okay? You seemed a little testy earlier." I hope my reassurance suffices, because I want him to schedule me more! More! MORE!
Uh, anyway. What with all the work, I miss my chance to appear in an IMAX movie[1] they're filming downstairs; among other things, they're attempting to re-create the landing and egress. But it's probably just as well: the world doesn't need to see my face on a screen the size of a city block. On a screen the size of a thimble, maybe that's something the world needs to see. But a screen the size of a city block, forget about it.
Tomorrow would be simpler than today no matter what, but once today's in the bag (with an hour to spare, mind you; maybe I really don't need to be such a jackass), Khaled and I get to work on tomorrow's sequences. Khaled hasn't built IDD sequences from scratch yet, and doing it with no time pressure is the right way to do it. He's come along really well, and is turning into a fine rover planner.
But he can't have any of my shifts. More. More! MORE!
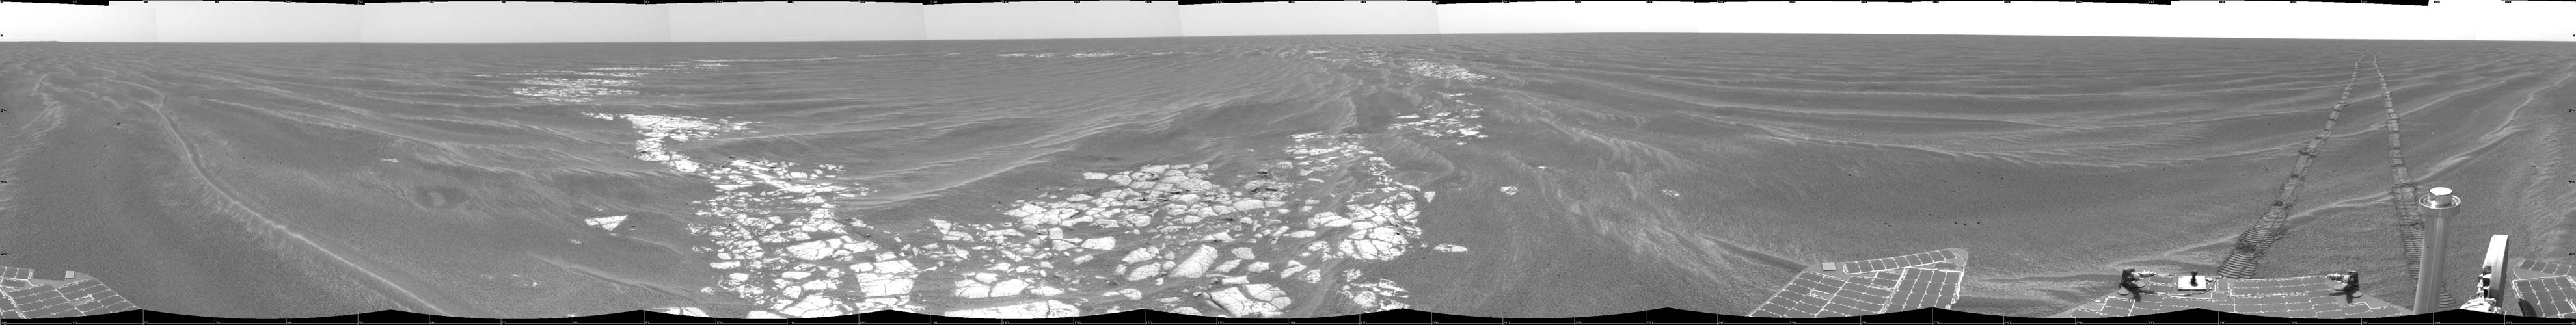
Courtesy NASA/JPL-Caltech; mosaic image hosted at Wikipedia. This is the entire 360-degree NAVCAM panorama, including (centrally) the broad ring of outcrop outlining what's left of Vostok Crater.
Footnotes:
[1] This, of course, was Roving Mars.
2010-03-09
Opportunity Sol 399 (Spirit Sol 420)
Yestersol's drive seems to have ended more or less where we meant it, about 35m from Vostok. But we have a goal error.
While Frank deals with the SOWG, I look into why we got the error. It turns out we didn't leave quite enough time for the worst-case end-of-drive housekeeping, and the worst case occurred yestersol. We timed out at the very, very, very end of the drive, a few seconds before we finished turning for comm. Literally another couple of seconds would have made the difference.
Oh, well. We're where we meant to be, and facing the right way, with only a little bit of egg on our faces. Thisol's drive is so simple that Frank effectively has it finished before the SOWG meeting ends: turn to 150deg and drive about 35m to Vostok, and that's about it. If it goes how it's supposed to, we'll end up with Vostok right under our wheels. If it goes the way the other recent drives have gone -- hell, we'll probably end up in the Pacific Ocean.
2010-03-08
Opportunity Sol 398 (Spirit Sol 419)
The good news is, we did a record-setting blind drive on sol 396. The bad news is, we didn't mean to.
The problem stemmed from a mistake in a waypoint command. A waypoint is actually a "waydisc" -- an imaginary circle on the terrain. The rover drives until it's inside the circle, or until it runs out of time trying. The mistake they made yesterday was that they moved the circle away but forgot to make it bigger, so the rover had to drive farther to reach it. What was intended to be a multi-stage 100m drive with increasingly paranoid suspension checks turned into a single-stage 125m drive with relatively generous suspension limits.
That could have been bad. It's not that we mind making more distance than expected, it's that the mistaken command sent the rover beyond what we could see well in the available imagery. If there had been a rover-killing obstacle out there, we could have sent the rover to its doom.
Luckily for us, the terrain the rover was driving over had no such hazards. (Admittedly, such hazards are rare in this terrain. But as Andy says, we're paid to be paranoid. And brother, we earn it.) Indeed, it stopped only because it ran out of time; if it had been given a couple more minutes to drive, it would have reached the circle anyhow, despite its greater-than-intended distance, and proceeded to the next command. That would have compounded the problem.
Frank needs no reminder that he made a potentially dangerous mistake. It's actually worse for him, because he almost caught it. He and Khaled noticed yesterday that something was screwy with the simulation, but they found a different error -- the rover's initial position was set incorrectly -- and thought that explained what they were seeing.
We've all had days like this. Yesterday it was Brian's and Frank's (and Khaled's) turn. I've had my turns, and I don't need another; they can have mine. Because one of these days, we're afraid we're going to come in and have to tell a story a lot like this one, except it will end with, "and that's how we killed the rover." Before the day is out, I have an automated check in place that will catch us if we make that mistake again. But Murphy's law is merciless: the number of potential mistakes seems infinite.
I try to cheer Frank up. "Still, you set a new blind-driving record! And it's one we're never going to break, at least not on MER!"
"Just what I needed," he groans, "my stupidity enshrined for all time in the Guinness Book."
I'm not very good at cheering people up.
Because the rover timed out while striving for the waydisc, the sol-396 drive didn't go as far as intended, and the sol-397 drive (an automatic continuation drive meant to execute Sunday) noticed the leftover error and, properly, didn't go anywhere at all. So we haven't quite made it to Vostok yet; today's just another long drive.
And believe me, we check the waypoint.
2010-03-06
Captain's Log, Supplemental
I'm proud and humbled and thrilled and honored to say that this blog was presented with the 3rd Spirit Award from UnmannedSpaceflight.com today. As I've posted there in my thank-you to the members of that excellent forum, I'll try to continue to earn it.
I'm also going to try to figure out how it's possible to be both proud and humbled at the same time. It doesn't seem like one could be. But I am.
I'm also going to try to figure out how it's possible to be both proud and humbled at the same time. It doesn't seem like one could be. But I am.
2010-03-03
Opportunity Sol 394 (Spirit Sol 414)
Cindy Oda's one of the nicest people I know, and she's going through a really rough time. Her mom's teeth are in really bad shape, and they're worried about her getting a bad infection. But they can't put her under to fix it because of some medication she's taking, and they're afraid to take her off it. Meanwhile, her husband, Jeff -- one of the other RPs -- has had to fly back to Illinois to deal with his own ailing dad, who has a heart infection or something like that.
So they're unhappy. Things like this make me almost feel bad about how well things are going in my life right at the moment.
Meanwhile, uh, things are going well in my life. (Sorry.) We're doing another uber-drive thisol. Actually, it's more of a mini-uber-drive -- no autonav. If we trip the suspension limits, we'll just have to stop.
I spent some time last night working out a prototype drive, which of course Khaled and Brian and I end up hacking up somewhat. Last night I didn't have time to analyze the past drives, so I wasn't really sure what limits to specify for this one. As the day wears on, Khaled and I keep thinking of something else we should check, look at the data, and interrupt Brian to tweak something else in the sequence. Tilt, bogie/differential limits at various points -- all of it comes up for review.
What we saw during the drive to Trieste was a tilt high-water mark of 11.5 degrees -- very close to the 12-degree limit that would have stopped the drive altogether. Both the tilt and suspension limits for that drive were higher than we've seen lately, which makes sense: we've been driving south, along the ripples, but the Trieste drive took us due west, straight across the ripples. So we were climbing up and down the ripples all the way. It's a wonder Opportunity didn't get seasick.
Because this drive took us somewhat off our intended southerly course, we're driving back to Vostok at a southeasterly angle. This is the worst of both worlds, as far as expected vehicle articulation is concerned. Not only will our tilt vary just as on the Trieste drive, as we climb up hill and over dale, but also our suspension will articulate more when we drive across the dunes at an angle than when we drove directly over them. This is unfortunate, as it means we may have to choose suspension limits that are hard to distinguish from what would happen if we encountered a real obstacle.
And that's a problem, because our drive-direction imaging is none too good. Usually we have good range data out to at least 80m or so, but thisol it peters out at 65m, and that's if you're being generous. Beyond that, we can't reliably determine a hazard from here, and if we can't tell the vehicle what one looks like in a way that distinguishes it from a ripple, we're in trouble.
In the end we decide, of course, to play it safe. We use more-generous-than-usual limits for the part we can see well -- that is, the part up to 65m -- and the usual paranoid limits beyond 65m. We'll probably make between 35m and 65m of progress, and then we'll have a data point that will be useful for planning the next drive. The next drive is going to be a weekend uber-drive series that should take us all the way to Vostok, or mighty close, so this will be very useful information to have.
Before Opportunity can start her drive to Vostok, though, she has to make it out of the crater. ("Crater," hah. Next to Eagle and Endurance, Naturaliste is a dimple.) Yesterday, when Frank and I were working ahead, I initially sequenced this egress using visual odometry. The strategy was a tried-and-true one: have Opportunity use VO to keep careful and highly accurate track of her progress, and stop when she's out.
Then we came up with the idea of using new R9.1 functionality[1] that can check for tilt. This seemed to let us express more nearly what we wanted -- we could have Opportunity drive until she's flat, assume that means she's out of the crater, and then proceed toward Vostok. We liked this better than the first approach, because we were worried the rover would yaw as she backed up, and end up on flat ground but not in the target zone. But if she only checked for tilt, we'd succeed no matter where she ended up, as long as it was flat. So I rewrote the whole thing to do it that way.
But today, when Khaled and I look at the data more closely, we see some problems with that idea. The area immediately behind Opportunity is flat, but the area just behind that has a largish ripple, one it would be easy for Opportunity to end up on. Given that she might be there, what tilt value do we choose to represent a flatness threshold? Too small, and the limit might be tripped because of the ripple, even though she had in fact egressed. Too large, and she might think she was out of the crater even when she wasn't. Neither of those outcomes would bring us joy.
Well, the reason we switched from a position-based approach to a tilt-based approach was that we were worried about yaw. And when we look at what happened on the way in, we see that Opportunity didn't yaw appreciably. Since we're backing straight up, leaving the same way we came in, she probably will do the same on the way out. In other words, yaw isn't likely to be a worry after all.
So I change it all back. Sigh.
Well, one thing I know for sure: if that's the worst thing that happens to me today -- and it is -- I'm damn lucky.
I'm damn lucky.
[Next post: sol 419 (Opportunity sol 398), March 8.]
Footnotes:
[1] That is, new functionality that had been added as part of the recent (R9.1) flight software upgrade.
2010-03-02
Opportunity Sol 393 (Spirit Sol 413)
I show up a few minutes late for the meeting (acceptable, since I'm RP-2 today), and Frank tells me he's already done. Not because he's a genius (though I'm not saying he's not), but because all we're doing thisol is a simple tool change -- one real command, the rest auto-generated boilerplate. (Just to leave my mark on the sequence, I change the 13.5cm backoff to 13.4cm.) It's going to be a slow day.
But that's okay. I expected that, and came in raring to do tomorrow's work, since we already know what it will be. I come up with the idea of combining the crater egress with the next drive toward Vostok (we had originally planned to do these two things in two sols); Ray likes the idea, so I go ahead and sequence it. One hopes this will mean tomorrow's a slow day as well, but you never know.
We're possibly going to rename RSVP for future missions. I suggest the name "R2" -- a nested acronym for "RSVP 2"; I love that it gives us an obvious mascot. Frank and I like it, at least. We'll see if it flies. Or, rather, drives.
2010-03-01
Opportunity Sol 392 (Spirit Sol 412)
Even though it's because I'm a dumbass (a patriotic dumbass, but a dumbass all the same), the rock we're IDDing is still named "Normandy." So when Albert Yen asks for suggestions for target names, I immediately suggest "Utah," "Omaha," and "Juno." I forget about "Gold" and "Sword," but no matter; the names stick. We'll be IDDing Omaha.
Jeff's father's very sick, so he has to leave town unexpectedly. Cooper gallantly volunteers to fill in, little realizing that he's already committed on Spirit (an unusual occurrence; no wonder he overlooked it in the schedule). So Jeng fills in for him.
It's a simple IDD day: unstow, then MI and MB Omaha; later, we change tools from MB to APXS. I could just about sequence it in my sleep. Because the generally flat rock surface is slightly uneven at the microscale, I get paranoid about the lateral MI move to take the stereo image, and sequence it in an unusual way -- the way we used to do it, by retracting the IDD farther from the surface before moving it over. In the end I decide this is simply too paranoid even for me, so I put it back to the usual way. Unsurprisingly, this prompts another discussion about the RPs and their relative paranoia. Jeng identifies himself as closer to the less-paranoid Wright/Leger end of the scale than to the Ashitey/Biesiadecki/Maimone end (which, it must be said, is where I locate myself). Since John happens to be here to ask, I ask him whether he considers himself or Chris to be the least paranoid RP.
He laughs, then thinks about it. "I am," he says. "But both of us -- well, both Chris and I feel that the rovers are more capable and robust than is generally acknowledged, let's put it that way."
Good spin. But I realize that even though I put myself on the more paranoid end of the scale, I must have some boldness when it comes to driving. After all, I'm currently the long-distance record holder for both rovers. I can't be all that much of a scaredy-cat.
2010-02-26
Opportunity Sol 389 (Spirit Sol 409)
The crater triplet is called Trieste. Which is in Italy. So why are the target names French? (And one's misspelled, at that: "Flinders" instead of "Flanders.") Beats me.
Matt was right, this area makes for a hell of a picture. Once we're into sequencing, I load up a section of the NAVCAM panorama covering the crater in front of us and the one beyond, and switch into 3-D mode. Doing this usually draws people to the workstation, and this time's no exception. One by one, the team members slap on a pair of 3-D goggles and stare in amazement at this inspiring sight.
I don't have much to do -- we turn for comm on sol 389, and then on 390 we turn back and descend about 70cm into the crater to get a patch of flat white rocks in our IDD work volume, so we can poke at 'em next week. Then they take out the comm turn (after I've sequenced it), so I guess that's one less thing.
I knew I'd be working with Jeff thisol, and he's conservative enough to be very nervous about entering the crater at all. So I applied a lesson from aikido: get into position. Last night I spent a couple of hours manually settling the rover to get a sense of exactly where it would end up when we bump forward. RSVP normally automates terrain settling, but that doesn't work in this case because we don't have terrain under the rover, and the software lacks common sense to tell it what unknown parts of the world look like. "Manual settling" means manually tweaking the modeled rover's position, attitude, and suspension until it's in a plausible configuration, perched realistically on the terrain. It's like a Rubik's cube: solving one part of the puzzle tends to disrupt your solution for the other parts, so you have to solve them all at the same time.
But I end up with a pretty reasonable picture, with the rover pitched about 7.5 degrees, and with an overall tilt of about 8.2 degrees. Figuring I'm wrong about some aspects of the solution, our final tilt might be as bad as 10 degrees. That's a bit high for soft sand, but not too bad; and the rear four wheels are all on level ground beyond the crater rim, which helps. I show the solution to Jeff, and most of his nervousness evaporates rapidly. Score one for aikido!
Justin Maki's been up to something characteristically ingenious, and today he shows it to me. It's an orbital map of our location, in the form of a terrain mesh we can load into RSVP. You can zoom way out -- and I mean way, way, way out -- and see the whole area around us, for kilometers in any direction. Just as a test, I go ahead and sequence a candidate drive to Vostok. With this new mesh, it takes no time at all. Then I do the 4.5km from Vostok to Victoria. This is going to be a hell of a good tool for these insanely long drives we've been planning. I'm so excited, I'm practically bouncing in my seat.[1]
But for now, it's the 70cm drive we've got to worry about. Surprisingly, nobody's named the flat white rocks we're driving to, so I suggest "Normandy," and the name sticks. I even attach a picture of the American cemetery at Normandy to the RP uplink report, and for good measure I include the poem "In Flanders Fields" and a picture of the American cemetery at Flanders.
This makes me curious about the target names they chose, so I start looking them up. That's when I realize I've been a total dumbass. The names are those of some French explorers and their ships, not of French places. And "Flinders" really is "Flinders," not "Flanders." The French explorers happened to meet up with Flinders -- a British explorer -- as they were mapping the coast of Australia.
This means "Normandy" doesn't fit into the namespace at all. If I'd known, I'd have suggested "Australia" instead. I quietly edit the uplink report ....
But that's not the only stupid thing I do today. Sean O'Keefe flew out for a picture with the MER team, and Jeff and I get so wrapped up in our work that we miss it. This means I've missed two out of three of the big team pictures (I also missed a recent one with the science team). If I didn't have my own picture with O'Keefe -- and if I hadn't been sitting right in front of him for the third picture, which I did manage to show up for -- I'd be seriously bummed out about this.
If anybody ever finds out how dumb I am, they'll take the rover away from me. And my car keys, and probably my shoelaces.
[Next post: sol 412 (Opportunity sol 392), March 1.]
Footnotes:
[1] These orbital meshes have become a standard part of our toolkit -- and they're even better now. The ones Justin was making came from MGS images; the new ones from from the even higher-resolution HiRISE camera aboard MRO. We can't rely on these meshes for all purposes: good as they are, they can't show you sufficiently detailed topography or all hazard-sized rocks, so we must always be able to prove a drive is safe in terms of images taken from Opportunity herself. Still, they're damned useful for context, and for showing that you're on the right general path, among other things.
2010-02-25
Opportunity Sol 388 (Spirit Sol 408)
It's a restricted sol -- no downlink until 15:00 or so -- so no rover driving today. But we're going to have a meeting at 16:00 to discuss the results, and get a sense of what we're going to do tomorrow in our weekend planning. (They decide to start at 07:30 tomorrow. Ugh.)
Before the meeting, I check out the images. We reached the craters! And we have a fantastic view; we look as if we're perched on the lip of one, with the other just beyond it. I don't see the third, but I'm not sure where to look. The rover's wheels are cocked hard to the side, which means we had a motion error somewhere; it should have straightened them. So something's wrong, but it went wrong in a pretty good place.
Mark Maimone sees me as I'm heading up to the meeting. "Jeff says the scientists are happy," he says. Well, that's the point of this little enterprise, so I'm quite happy to hear it.
Upstairs, while Matt Golombek effusively praises the results, I'm getting a different picture. They wanted to end up between the two southern craters, but that's clearly not where we are: we're looking to the west and seeing two craters, which can happen in this triplet only if we're to the east of the southeastern crater, not between the southeastern and southwestern craters. I try several times to point this out to Matt, but he's not listening, and eventually I give up. If they're happy, what does it matter?
Our original plan had been to head southeast for the weekend, so that we'd arrive at Vostok Crater on Monday. But the scientists like the view from here, so we're going to delay that a week or so. In the interim, we'll hang out here, imaging the craters and maybe doing a little IDD work.
And, since flash is filling, we'll downlink as much as possible. As one of the scientists points out, there's not much point in getting to Vostok early if we don't have flash space to take any pictures or to do any other work once we get there.
As the meeting is wrapping up, Matt figures out what I've been trying to tell him, that we're not where we thought we were. "Oh, well," he shrugs, "it's still one hell of a spectacular spot."

Courtesy NASA/JPL-Caltech. Matt was right: although this wasn't quite where we wanted to end up, it's a spectacular spot.
Before the meeting, I check out the images. We reached the craters! And we have a fantastic view; we look as if we're perched on the lip of one, with the other just beyond it. I don't see the third, but I'm not sure where to look. The rover's wheels are cocked hard to the side, which means we had a motion error somewhere; it should have straightened them. So something's wrong, but it went wrong in a pretty good place.
Mark Maimone sees me as I'm heading up to the meeting. "Jeff says the scientists are happy," he says. Well, that's the point of this little enterprise, so I'm quite happy to hear it.
Upstairs, while Matt Golombek effusively praises the results, I'm getting a different picture. They wanted to end up between the two southern craters, but that's clearly not where we are: we're looking to the west and seeing two craters, which can happen in this triplet only if we're to the east of the southeastern crater, not between the southeastern and southwestern craters. I try several times to point this out to Matt, but he's not listening, and eventually I give up. If they're happy, what does it matter?
Our original plan had been to head southeast for the weekend, so that we'd arrive at Vostok Crater on Monday. But the scientists like the view from here, so we're going to delay that a week or so. In the interim, we'll hang out here, imaging the craters and maybe doing a little IDD work.
And, since flash is filling, we'll downlink as much as possible. As one of the scientists points out, there's not much point in getting to Vostok early if we don't have flash space to take any pictures or to do any other work once we get there.
As the meeting is wrapping up, Matt figures out what I've been trying to tell him, that we're not where we thought we were. "Oh, well," he shrugs, "it's still one hell of a spectacular spot."
Courtesy NASA/JPL-Caltech. Matt was right: although this wasn't quite where we wanted to end up, it's a spectacular spot.
2010-02-24
Opportunity Sol 387 (Spirit Sol 407)
Alicia Fallacaro's the KOP -- the Keeper of the Plan -- and since the KOP runs the software that acts as our planning whiteboard, we can't get started without her. When she comes in, Matt Golombek scowls at her. "You're three minutes late!" "That's OK," I tell her sotto voce, "you saved the rest of us from being late -- we all just got here." This sparks an idea in Brian: on early mornings like this, we should pick some crucial team member to be "the late one," so everyone else can straggle in a little late without being so noticeable.
But it doesn't take long for Matt's mood to improve. "The rover planners should be severely applauded for their great work this weekend," he says. (Well, "severely applauded?" Maybe his mood's not so good, at that.) We did about 389m total for the three-day weekend, shattering records. The first slide the Long-Term Planning lead puts up is a diagram showing how this insane megadrive has affected us. There's a line on the diagram showing how much cumulative progress we'd have to have made each sol in order to get to Vostok on schedule, a straight line running diagonally up the slide. The other line shows our actual progress. It lags well below the target line, and then, this weekend, suddenly shoots up vertically, putting us well ahead of schedule.
"Holy cow!" says one of the remote scientists, voicing my thinking exactly. "I haven't seen a diagram like that since back in the Bonneville days!"
Yeah, I remember those days. The days when we thought a 70m drive was really impressive. Thisol we're going for about 90m, and it doesn't feel like much. However, we're not heading south, to Vostok. Instead, we're cutting west, to a crater triplet dubbed "Trieste." Our imaging is lousy, and even if it were better, we wouldn't have very reliable range data at that distance. But the drive azimuth is a doddle to determine, and Tim Parker has done a localization in the orbital data, which should tell us the desired drive distance.
Note that I say "should." As in, should, but doesn't. This is because Tim's in San Diego, and Matt forgot to write down what Tim told him.
Fortunately, Tim has a cell phone, and Matt's able to find him. We work out the azimuth and direction of the actual desired destination, and that's it. Except that Mark Maimone stops by immediately before the walkthrough, and we end up changing half of the sequence.
Oy.
2010-02-20
Opportunity Sol 384 (Spirit Sol 404)
Once again, I'm in on the weekend -- rather, on a holiday, this time -- to check Opportunity's progress and ensure she's safe to continue. The images show up a few minutes after I do, and again they show a clear road ahead. She put about 104m on the wheels thisol, all of it autonav. I don't know whether we set an autonav record yestersol, but if we did, we beat it thisol. In any case, this is definitely a record; whatever the previous autonav max was, I know it was under 100m.
Once again, we're ready to let the rover proceed on her own for an entire sol. Mark's happy, Art's gleeful. And I'm euphoric.
[Next post: sol 407 (Opportunity sol 387), February 24.]
Once again, we're ready to let the rover proceed on her own for an entire sol. Mark's happy, Art's gleeful. And I'm euphoric.
[Next post: sol 407 (Opportunity sol 387), February 24.]
2010-02-19
Opportunity Sol 383 (Spirit Sol 403)
We got the downlink from the first of our weekend drives. This is the combined blind + autonav drive. Mark Maimone and I sit in the SMSA, looking at the downlink. The images show that the way ahead is totally clear, all the way to the horizon. So whatever else we see in the downlink, this is pretty much enough to tell us we should proceed on the next sol.
But how far did we get?
"177.5m total," Mark reports. "About 105m blind, 72m more autonav."
Oh, well, I say to myself philosophically. It would have been nice to set the record, but at least -- "Hey, wait a minute!" I exclaim. "That is a record!"
And it is. Indeed, it's at least two records. The previous single-sol total was 156.55m, so we beat the heck out of that. And the previous single-sol blind-drive record was about 92m; we beat that too. I don't know what the single-sol autonav record was, but I wouldn't be surprised if that's a third record broken. They won't last long, but it's nice to hold the records once again.
We actually got some bonus blind driving. In order to help the rover keep itself safe, we increasingly tightened its suspension limits the farther out it got: if it tried to drive over something too tall, or into something too deep, the suspension would articulate beyond the limit and the blind drive would stop. Then the sequence would automatically clear the error, back up into presumably safe territory (it had just driven through that area successfully), and continue on autonav. That way, even if the blind drive faulted out, we'd be able to use autonav to salvage part of it.
As it happened, the suspension limit triggered at the very end of the blind drive, as the rover was turning around to switch from blind driving to autonav. So it had already completed the entire planned blind drive, and then we got a few bonus meters on the wheels as it backed up.
We simply couldn't have planned this. Art agrees, when I call him to tell him the great news: "This is just too good!"
2010-02-18
Opportunity Sol 382 (Spirit Sol 402)
We planned two sols yesterday, and we're planning three today -- for President's Day Weekend. Saturday, Sunday, and Monday are all going to be drive days.
And what drive days! Friday, we do one hour of blind driving followed by 2.5 hours of autonav. Saturday and Sunday are each four hours of autonav -- we'll just let the rover pick up where it left off the sol before, and continue to find its own way south. The combined total distance for the three sols might be 350m, possibly even more! As Justin Maki points out, we'll basically do two-thirds of our mission success driving in one weekend.
Fitting all this driving in is going to require some work. They'd originally planned to spend the rest of each sol doing some remote science, but our power situation is such that we can't. So the science team ruthlessly cuts science until the drive fits. We have to cut some of the post-drive drive-support imaging, but it's not a big deal. As long as we get the drive-direction FHAZ images, we'll be fine. And we'll get NCAMs on top of those, so we're gold.
The rover's continued (Saturday and Sunday) driving will be autonomous, but depending on what we see in the downlink, we could want to pull the plug. So we'll have to come in over the weekend, just long enough to evaluate the downlink and say whether we think it's safe for Opportunity to go on. Theoretically, we might decide on Monday that we need to re-plan the drive, but that doesn't look likely. Nobody wants to call the team in on a holiday anyway.
We plan the drive. We cross our fingers. We go home.
But not before saying goodbye to Julie Townsend, who's moving on to other work. She hugs Art and tells him she's had the time of her life. "I know what you mean," he says. "You work on something like Pathfinder, and you think nothing will ever be like that again. And then something like this comes along."
2010-02-17
Opportunity Sol 381 (Spirit Sol 401)
Thisol we're completing our IDD work on Russet, after which we drive to the Alvin and Jason craters.
The drive to Alvin and Jason is my first time planning a drive using orbital imagery. We don't have good enough NCAM or PCAM imagery to reliably drive as close to the craters as we want, so at Jeff's suggestion, Brian and I go downstairs to work with Tim Parker to plan the drive. He's basically got an imaging program with the rover localized to a point in an orbital picture, and he can draw lines of various lengths and at different angles. He's clearly been getting a lot of practice: with his help, it takes just a few minutes to work out the drive.[1]
Sadly, the science team has decided they want to drive between the craters after all (not skirting them by driving south of Jason, as I'd suggested a few sols ago). On closer inspection of the imagery we do have, the crater my plan would have avoided turns out to be the more interesting one, as it appears to contain outcrop material. But that's OK, this isn't our big drive sol.
Our big drive sol comes next. Or, more accurately, our series of big drive sols. We're going to head south in a big way, continuing to Vostok by way of a cluster of three craters more than 300m south of us. Though I doubt this is possible, I'm hoping to make it there in two sols, which would almost certainly mean breaking the distance record once more (however briefly, before it's broken again). For the record -- no pun intended -- the current single-sol drive-distance record is 156.55m. I'll have a few chances to break it. Even if I don't succeed, it'll be fun to try.
[1] A much-refined version of this approach has become the norm for Opportunity's long drives across Meridiani Planum -- as we're doing now to make our way to Endeavour, for instance. Tim Parker and Matt Golombek lay out a large-scale traverse path, and the RPs make tactical decisions about how closely to follow it, based on what we actually see from the surface each sol.
2010-02-16
Opportunity Sol 380 (Spirit Sol 400)
The good news is, we're in that phase where our start time is slipping later and later. The bad news is, I have to come in early today anyway, for a meeting. At least it's something MER-related: it's Jeff and Mark bringing us RPs up to speed on the new mobility flight software. (Just to twist the knife, Frank suggests a way to surreptitiously use one of the new features to ensure I don't get a chance to drive very far. "The way things have been going," I reply wryly, "it's not like you have to work hard to ensure that.")
After that, it's a relatively slow day in RP-land. Russet ended up dead ahead of us, just where we wanted it, in a perfectly cromulent spot for IDDing. We're just going to MB and APXS it thisol. It takes me maybe half an hour to crank out the sequences.
At least I got to name something again. In keeping with the potato theme, Albert Yen named one of the targets "Eye." Then, working down the side, he named two more targets "Nose" and "Mouth." We ended up choosing a location between Eye and Nose, which I named BridgeOfNose.
Well, as I said, it was a relatively slow day.
2010-02-15
Opportunity Sol 379 (Spirit Sol 399)
Charles has a beautiful shiner. I can't resist asking him about it.
"Friday was not a good day for me," he says. "I was driving through Old Town Pasadena, turning down Fair Oaks, and I hit a pedestrian. I got out of my car to check on her, and this guy yelled, 'You hit her!' and sucker-punched me." He mimes throwing his head back as a result of the punch. "That was his contribution to the situation. I've got problems, but he has a felony assault charge."
Yee-ouch.
Yesterday they ran a checkout of the new mobility flight software. It looks like it generally went well. At least the vehicle didn't die. And it ended up near where it was supposed to. But not quite where it was supposed to -- it's about 1.8m away from its intended destination, a ten percent error or so, and Jeff and Mark aren't sure why. It might be something as benign as simple error in the previous sols' images -- that is, the things in the world might not have been exactly where we thought they were, which would explain why they're still not, if you see what I mean. But until we're sure, we don't want to go much of anywhere.
Which is fine by the scientists. The intended target of our drive, a possible meteorite dubbed "Russet" (as in the potato), is directly in front of our right front wheel. So thisol's drive is just a turn in place, to put Russet in our work volume. It takes me barely five minutes to write it.
That gives me some time to participate in the planning for the upcoming drives. If I'm lucky, by the end of the week we'll be back to the routine of long driving I missed the last round of. I might yet get my shot at another record! (Probably not -- we likely can't outdo what's been done -- but at least for now I can hope.) Our next near-term goal will be to skate between a couple of craters currently about 40m southwest of us, stopping on the way by to image them. Then we'll turn more to the south and floor it.
As usual, there's a problem. The craters are far enough apart that we won't be able to image both of them well from a single spot. Ray and the other scientists say they're more interested in the southern crater, so I suggest a different plan. My idea is, don't bother going between the two craters and then turning south. Just go to the south of the southern crater, image it from relatively close (and image the other one as well as we can), and move on. This takes us less far out of our way and gets them equivalent results.
"Scott's pretty smart!" Ray exclaims. "I'm glad you're here, buddy!"
No doubt about it: I'm definitely having a better day than Charles.

Courtesy NASA/JPL-Caltech. Russet is just in front of Opportunity's RF wheel. You want me to drive all the way to Russet? In just one sol? Well, I do like a challenge ....
"Friday was not a good day for me," he says. "I was driving through Old Town Pasadena, turning down Fair Oaks, and I hit a pedestrian. I got out of my car to check on her, and this guy yelled, 'You hit her!' and sucker-punched me." He mimes throwing his head back as a result of the punch. "That was his contribution to the situation. I've got problems, but he has a felony assault charge."
Yee-ouch.
Yesterday they ran a checkout of the new mobility flight software. It looks like it generally went well. At least the vehicle didn't die. And it ended up near where it was supposed to. But not quite where it was supposed to -- it's about 1.8m away from its intended destination, a ten percent error or so, and Jeff and Mark aren't sure why. It might be something as benign as simple error in the previous sols' images -- that is, the things in the world might not have been exactly where we thought they were, which would explain why they're still not, if you see what I mean. But until we're sure, we don't want to go much of anywhere.
Which is fine by the scientists. The intended target of our drive, a possible meteorite dubbed "Russet" (as in the potato), is directly in front of our right front wheel. So thisol's drive is just a turn in place, to put Russet in our work volume. It takes me barely five minutes to write it.
That gives me some time to participate in the planning for the upcoming drives. If I'm lucky, by the end of the week we'll be back to the routine of long driving I missed the last round of. I might yet get my shot at another record! (Probably not -- we likely can't outdo what's been done -- but at least for now I can hope.) Our next near-term goal will be to skate between a couple of craters currently about 40m southwest of us, stopping on the way by to image them. Then we'll turn more to the south and floor it.
As usual, there's a problem. The craters are far enough apart that we won't be able to image both of them well from a single spot. Ray and the other scientists say they're more interested in the southern crater, so I suggest a different plan. My idea is, don't bother going between the two craters and then turning south. Just go to the south of the southern crater, image it from relatively close (and image the other one as well as we can), and move on. This takes us less far out of our way and gets them equivalent results.
"Scott's pretty smart!" Ray exclaims. "I'm glad you're here, buddy!"
No doubt about it: I'm definitely having a better day than Charles.
Courtesy NASA/JPL-Caltech. Russet is just in front of Opportunity's RF wheel. You want me to drive all the way to Russet? In just one sol? Well, I do like a challenge ....
2010-02-09
Opportunity Sol 372 (Spirit Sol 393)
The scuff worked out just as intended and is now in front of us, perfectly positioned for us to IDD it. But Rick Welch suggests abandoning this opportunity. We have a new FSW load coming up, and he thinks it might be a good idea to get the rover into a good attitude for that. We wouldn't leave the scuff altogether, but we'd try to drive to a different location, one from which we could still reach the scuff while being better positioned for the FSW load.
But the science team nixes the idea. "We've got this," one of them says, "let's use it."
Well, they won't have Rick to kick around any more. Not for long, anyhow. He's moving on to MSL after this week, and Julie Townsend is doing the same. "The last remnants of the original team are floating away," she muses.
Speaking of MSL, Jeff heard a disturbing rumor. The flight software architecture for MSL, he heard, is going to be based on a system called VML. Nothing wrong with that -- if you have an orbiter, or even a lander. But for a rover, VML doesn't make sense. This is because VML requires every command to be time-tagged; it doesn't seem (says Jeff) to have an event-driven mode. (That's what we call a mode that says, "do each command as soon as the previous command finishes.") That's the mode in which we always command the rovers. Time-tagging all commands makes sense when you have an orbiter, whose environment can be perfectly predicted months in advance, or even a lander, whose environment is more or less fixed. But for a vehicle that has to dynamically respond to an unpredictable environment, this would be absurd.[1]
And maybe it's not true -- we don't know enough about VML to know. "One good thing if it is true," I point out. "It'll sure help me decide if I want to work on that project."
[Next post: sol 399 (Opportunity sol 379), February 15.]
[1] I don't know whether VML was ever seriously in contention as the basis for MSL's flight software or if this was simply a baseless rumor, but in any case VML is not being used on MSL.
2010-02-08
Opportunity Sol 371 (Spirit Sol 392)
Oddly, we have no images from sol 369. We know the rover's not dead; we have images from sol 370. But for 369, nothing but thumbnails. It makes an odd gap in the data -- I don't remember ever seeing that happen before. They'll come down eventually, but not until our downlink improves.
Thisol we're going to finish up with the damn trench already. Still, we're not ready to leave. (Hell, we wouldn't want me to drive somewhere -- I might get a chance to break a record. Grumble, grumble.) Since we couldn't IDD the scuff we made earlier, we're going to make another one and IDD that. The last one appeared to dig farther into the soil than they'd wanted, so this one's going to be simpler and shorter: we'll just run the left front wheel back and forth a bit, then back off and turn.
Or that's Rob Sullivan's plan. But Julie points out that that will leave the rover at an azimuth of 210 degrees -- not bad for comm, but we could do better. "Better" would be a radically different heading, 80 or 90 degrees -- split the difference and say 85 -- where we'd get 100 Mbits more downlink each sol. 100 Mbits is a lot of saved-up images, so I start thinking about how to accomplish this.
We can't scuff just anywhere, we need to ensure that the wheel's not on a ripple. Our view of the immediate area isn't that great, so to ensure success, we really want to scuff the spot where the left front wheel is now. In order to be at 85 and IDDing the scuff, the spot we need the rover to be in is in front of us and to the right of where we are now. If we scuff and then drive to that spot, we'll either drive through the scuff, contaminating it, or through the trench, which they haven't finished imaging yet.
It's time for a creative solution, and I think of one: don't scuff with the left front wheel, scuff with the left rear wheel, after putting it where the left front wheel is now. That is, instead of scuff/drive forward/turn/back off, we could drive forward/scuff (with rear wheel)/turn/back off. By design, the trench is just a bit narrower than the wheel base, so we can even do this without disturbing the trench -- we'll just straddle it.
While Jeff writes the IDD sequences, Jeng and I develop the drive, but in the end it simply proves too complex. This is already our second try at the scuff, and nobody wants to have to make a third -- even the scientists are ready to drive on. As much as I love my idea (and I'm not the only one), it's not The Simplest Thing That Could Possibly Work. So we revert to Rob's original plan: scuff, back off a bit, and turn. Simple, effective -- and, unfortunately, 100 Mbits/sol less downlink.
In refining the scuff part of the drive, we introduce an unusual move. The original idea was to run the left front wheel backward, to kick away any material it might have tracked in underneath it, then run it forward to create the scuff, and then back up. But in order to help create a clean scuff, we need to drive the rover back very slightly, just a centimeter or so.
At first, Jeff's not even sure such a short drive will work. But it works fine when we run it through the simulation, so he shrugs and blesses it. He turns to me and says, "I don't think we've ever done a drive that short on Mars. Hey, I guess you got to set a record after all!"
Gee, I'm so proud.
2010-02-05
Opportunity Sol 368 (Spirit Sol 389)
Thanks to the frenzy of yesterday, the pressure is somewhat reduced today. Today's uplink was done yesterday, so today (Friday) we just have to do Saturday's and Sunday's uplinks. It's just as much work, but we can run late if we have to.
Our downlink must be poor. We've only gotten one MI so far, but it looks spectacular. Unfortunately, it doesn't quite cover the area the scientists wanted. RSVP showed we should expect to just see over the top of the trench, which is exactly what they asked for, but it seems the image we got is somewhat farther down the trench wall than that. It's not clear we've got enough room in the plan to reshoot them today, but we'll have to reshoot them before leaving because they're probably the highest-priority scientific target in the trench. Between that, and the MB team's deciding that they want additional integration time in the trench for better statistics, they decide to change the plan. We won't bump to the scuff on Monday, we'll continue our trench work.
This sucks for two reasons. First, it means we need to redo a large chunk of the plan, which in turn means not only that we wasted a whole bunch of time yesterday but also that we're going to have that much less time for sequencing today. Far more important to me, though, is that this means I won't get a chance for a long drive in this cycle of shifts. I'm on only until Tuesday, and then I'm off shift again for about a week. I was really pushing to get all of the trench work finished by Monday, but with the decision to spend an extra day at the trench, we'll finish Tuesday instead. So I'll have spent this entire shift cycle screwing around with the trench, and the RPs who come in after me will be doing the fun record-setting drives, while I spend that time slogging through some decidedly dull MSL-related work.
Worst of all, I have nobody to blame for it but myself. MB notwithstanding, I doubt we'd spend the extra time here if the MIs had covered the desired area. And guess who took the MIs.
Intellectually, I can see that I'm being churlish about this. (Oh, woe is me. I get paid to play with a Mars rover, but I'm not driving it very long distances right at the moment. My life is such a misery.) But knowing that doesn't seem to improve my attitude -- to the contrary, it's making it worse. I might need to take a couple of days off.
So might Matt Golombek. He's having a hard time wrangling the scientists, so the SOWG meeting is going slowly. He turns around to face the engineering team (us), which sits along the row behind him. "Damn scientists!" he blurts out -- only half-kidding, if I'm reading him right. "Welcome to the back row," replies fellow engineer Geoff Lake.
As expected, today's another long day. Jeff and I improve our process -- we develop the two sols in parallel, as we did yesterday, but we exchange sequences earlier in the day, which I think makes a lot of difference. Once again, the TULs and TAP/SIEs have to work through a variety of software problems, but at least we've figured out why this keeps happening.
It's happening because we're improving things. Sharon Laubach has been developing a bunch of scripts for automating the ground system. Mostly, she develops these in her home directory, and then at some point she informally delivers them to the team by putting them in a semipublic location. At the same time, she starts the process of delivering them to Configuration Management, who's responsible for installing them officially on all the systems. CM just officially installed her new stuff, so Sharon duly removed her semipublic copies.
The only problem is, CM installed her new stuff on the Suns only, not on the Linux systems. Most of our work gets done on the Linux systems. So a lot of stuff broke.
The team's collective opinion is that CM needs to take a few days off, too. And not come back.
[Next post: sol 392 (Opportunity sol 371), February 8.]
2010-02-04
Opportunity Sol 367 (Spirit Sol 388)
The good news is, there's a beautiful trench right in front of us, just where it should be. The bad news is, the scuff we made before trenching is unreachable.
They wanted to be able to hit four targets: the trench (wall and floor), the ripple crest, undisturbed soil next to the ripple, and the scuff. We got three out of four. Not nearly good enough. I feel lousy.
But one thing I've learned is that there's a time and a place for self-reproach, and the thick of ops ain't it. There will be plenty of time to beat myself up when we're done with thisol's sequencing.
And there's a lot of that to do. We're going to sequence two sols today, and two tomorrow, so we won't have to work Saturday. Thisol (367) we're going to MI the far wall of the trench, right at the boundary between trench and sky. The chosen area is a cross-section of the ripple, so we'll be able to tell what the ripples are made of. Then we place the MB in the trench, and later we switch from the MB to the APXS, doing an MI sky flat during the transition.
Nextersol (368) -- which we're also planning today -- we'll MI the trench floor, where we placed the MB and APXS, then MI the ripple crest and MB it.
Matt Golombek, the SOWG chair, wraps up the SOWG meeting. "That's a lot of work, and we're going to have just as much tomorrow. Anybody think we need to start before 8:30?"
"No," I say nonchalantly from behind him. My non-morning-person status is well known, so this provokes a laugh. But Matt accepts the suggestion, which emboldens me. "In fact, we could start at 9:30 or 10:00," I continue.
"We'll start at 8:30," Andy says, and that's that.
Frank brought some Japanese visitors to watch us at the SOWG meeting, and they're in the sequencing room when we get there. They're from Toshiba's space division, or something like that. They give me their business cards, and I give them mine. ("Domo," I say when they hand me their cards. "You speak Japanese?" the man asks in surprise. "Just a few words I've picked up in the dojo," I answer. I feel like a dumbass.) The woman actually looks at my card, and notices what's printed there. "Look!" she exclaims to the other guy. "It says 'Mars Rover Driver' on it!" They look at me with some mix of admiration and envy. I bet they wish their business cards said that!
We have about twice the normal workload today, so Jeff and I split it up -- I take 367, and he takes 368. Jeng hasn't done a lot of IDD work yet, and is trying to figure out which of us to watch. I'm almost done, so I suggest he watch Jeff -- that way, Jeng can see a sequence done from scratch.
But the more work I do on the sequence, the more I realize I'm not done after all. Since both vehicles have developed a problem with opening the APXS dust doors, we've been leaving them open for the last several months, and we have to be careful not to close them. (If we close the doors and can't open them again, the APXS becomes effectively useless. As a result, we lose much of our ability to determine the chemical makeup of rocks and soil, which would be a serious blow to our science capabilities.) There's not an explicit command for closing the APXS doors; you do it by rotating the turret almost all the way to one of its hardstops.
What I hadn't realized when first writing the sequence was that when I'm placing the MB in the trench, it's coming in at an angle that will rotate the turret to the point of closing the APXS doors.
Oh, shoot.
But this problem is masked for a while by another one: RSVP is reporting a collision error. Usually, this is due to one of two things -- either a self-collision, where the turret rotates through the forearm, or a collision between the IDD and the rover deck. But neither of those appears to be the case here. I'm puzzled until I think of turning on RSVP's collision-volume display, and then the problem pops out at me quickly. It thinks the arm is colliding with the wheel.
This seems ridiculous at first blush -- the IDD doesn't appear to be coming anywhere close to the wheel. But the collision volume for the wheels extends tens of centimeters above the normal settled position of wheels themselves, reflecting the fact that the front wheels can rise as the suspension articulates. At maximum extension, the IDD's elbow, of all things, grazes the top of the collision volume.
Working around this requires some care, but it's not bad. We have macros to turn the wheel collision volume on and off, thus automating the really hard part.
All told, it ends up taking several hours to work through these problems. Good thing I was almost finished several hours ago, or I wouldn't have gotten done at all.
Ahem.
Jeff and Jeng are finishing up about the same time I am. We're late, but we're not the ones holding up the process -- the TULs and TAP/SIEs have been working through a variety of tool problems. But we're on the critical path now; uplink is in just a couple of hours. And we're not finished -- at least, we haven't taken the critical step of reviewing each others' sequences.
"You've got no margin on the walkthrough," Julie warns us. "And you have to deliver right after." So we're going to have to get this right.
Jeff and I swap off and review each other's work. Either we're both idiots or both brilliant, because neither of us finds a significant problem in the other's work. Despite our needing to change the sol-367 MI target at the very, very, very last minute, we're ready for the walkthrough ten minutes early, which is like gold in the hand at this point.
So we start the walkthrough ten minutes early, and it goes well, and then for us RPs it's all over but the shouting. At this point, we mainly have to wait for the TAP/SIEs to turn the crank. We take a few minutes for a post-mortem.
"So was that too hard?" Golombek asks. Jeff says he feels like it was just about right, but I don't -- I don't really feel like we had enough time to review each other's work. Maybe we can do it better tomorrow, since tomorrow will be much like today.
"You know, today reminded me of nothing so much as a primary mission sol," Julie observes. "It was that crazy, things changing that much."
"But if you think about it, we're about four times as good as we used to be," I point out. "We just did two sols, in about half the time it used to take us to do one."
"Better than that," Andy adds. "We're doing it with fewer people now."
As the conversation inevitably digresses, Andy relates an amusing tidbit. MRO wants our (Opportunity's) sequencing room. Their idea is that Opportunity would move downstairs, into the now largely unoccupied science meeting room.[1]
But the sequencing rooms have special facilities requirements, what with all the videoconferencing equipment and such. This makes a move unusually expensive, and MRO can't pay for it. Not because they don't have enough money, but because it isn't distributed properly -- unless they want to violate their contract with NASA (and believe me, they don't!), they don't have a budget category that would enable them to pay for the move. And MER won't, or can't, pay for it. So we get to stay here. Saved by the budget.
Uplink's at 17:30. We finish the CAM at 18:40, 50 minutes to spare.[2] It's hardly even dramatic.
I bet we could have sequenced one more MI stack ....
Footnotes:
[1] Instead, this became a MER cubicle farm. We still have that sequencing room.
[2] It was obviously a long day, because my original notes are plainly wrong here. Clearly, one of these times is off by two hours: either uplink was at 19:30 and we finished at 18:40, or uplink was at 17:30 and we finished at 16:40. At the remove of five years, I'm not sure how to find out which it was, so you'll probably have to struggle through your life bearing the uncertainty.
2010-02-03
Opportunity Sol 366 (Spirit Sol 387)
So the last sol I was on shift, we drove 70m or so away from the heat shield, just to get the rover well clear of it. Since then, every sol's been devoted to charging across the plains as fast as possible, doing drives so long they have to plan them with orbital maps. My single-sol blind-driving record is gone, never to return (the bastards just had to take that away from me, breaking my record by a meter or so), and the single-sol total-distance record is now up to 154m or so. But now it's my turn again, and I'm ready to floor it.
So of course, they picked today to stop and IDD for a while. We're going to dig a trench and poke around in it, right up through my last day in this group of shifts. Then they're going to drive some more.
No, I'm not kidding. I couldn't make this up if I tried.
One of the scientists, Rob Sullivan, already worked out most of what needed to be done. We have a lot of analysis to do, but really, he's done most of the hard work for us.
Not that this stops him from being genuinely appreciative of our work. "You guys are just great," he enthuses over the telecom. "Really, if people knew all the stuff you guys have to do every day ...." He continues in this vein for a full minute, maybe more. It's wonderful -- it almost makes up for not getting to do a long drive. After listening to Rob's effusion of praise, Andy replies, "Remember this at performance evaluation time!"
If Rob is appreciative, Frank is sympathetic. He stops by to see how things are going, and I complain (reasonably good-naturedly) about my getting shut out of the driving. "I feel for you, man," Frank says.
"So you'd be willing to trade some shifts with me?" I tease him.
"I'm not gonna lie to you," he says. "When I saw the upcoming plan, I was like, thank God I'm off for those few days."
At least he's honest about it. "I can't blame you," I shrug. "If the situation were reversed, I have to admit I'd feel the same way."
Well, one of the great aspects of my job is that even on the worst days -- even on the very worst days -- I get to drive a Mars rover. And that's not what I'd call bad.
2010-01-25
Opportunity Sol 358 (Spirit Sol 378)
It's January 24th. Opportunity has been on Mars one year today. Unlike Spirit's birthday, there's little fanfare, just people getting on with the job. And occasionally reminding each other, with the usual subdued wonder: we've been at this a year.[1]
So it's the beginning of Opportunity's second year on Mars, and the end of something else: namely, it's the end of our exploration of the heat shield. ("And there was much rejoicing ....")
I know, I said that last time. But this time, I really mean it. We planned the post-heat-shield drive, but there's one more thing they want us to do before we go. The MI images we got over the weekend looked great (I'm a genius!), but shooting them through the dust cover, as Erickson mandated to protect the instrument in case I screwed up, reduced the contrast. So the EDL team wants us to retake a few of them with the dust cover open. (To my surprise, Erickson agrees to this. I think that's to his surprise as well: "I said 'no' originally" he tells me, "but Squyres argued me around." Which is yet another surprise: the heat shield being primarily of engineering interest, the project has been generally unwilling to subject the rover to any risk over it -- for example, we can't use any of the instruments except the MI.) After that, we'll stow the IDD and drive away, as planned last week.
We're actually damn lucky we got anything at all. Last week, while building the sequences, there was a mix-up about which MI image sequences we were supposed to call. The first version of our IDD sequence used the wrong MI sequence IDs, but we redelivered a newer IDD sequence with the right MI sequence IDs in it. So far, nothing particularly unusual. But somehow, they managed to send the wrong version of the IDD sequence to the spacecraft! (We have software to warn about this, but they somehow managed to overlook the warning. Yeesh.) Happily, the "wrong" MI sequences were already on board, having been left over from some long-ago sol, so the spacecraft was happy -- it took images with a somewhat suboptimal exposure, but at least it took them.
But that was just dumb luck. It could easily have been otherwise: we could have moved the IDD to all the right places, and taken no pictures. Or, if the difference between the two IDD sequences had been something else, arbitrarily bad things could have happened. Lucky, lucky, lucky ....
At least thisol's sequencing is relatively easy. The drive's already in the bag, and the IDD stuff is just a subset of what we did over the weekend, so it's mostly a matter of copying and pasting. It doesn't take me very long to get it done. Which is great, because it leaves time for the Iowa Space Girl.
The Iowa Space Girl is Susan Kurtik's seven-year-old grandniece -- "she's bonkers about space," Susan says.[2] The Iowa Space Girl is also known as "Abigail," and I spend about half an hour showing her and her family around the MER area, letting her look through the 3-D glasses at Mars, letting her play with RSVP, and so on. Kids love RSVP, because it's like a video game -- which was the idea. "Scott got to grow up and get paid to write video games, and then he gets paid to play them," Susan says.[3] Abigail seems to like this idea.
Abigail seems like a great kid -- polite, smart, genuinely interested in space. But Steve Squyres is a big kid, too. On his way past he picks up a pair of the 3-D goggles and peers through them at the heat shield. "Gosh, what a weird-looking thing!" he exclaims. "A crashed spaceship on another planet!"
"Shame it's ours," I say.
He laughs. "Now that's a circumstance under which I'd be willing to use the APXS on it. APXS, MB, everything!"
[Next post: sol 387 (Opportunity sol 366), February 3.]

Courtesy NASA/JPL-Caltech. One of the MI images of Opportunity's heat shield. So, this robot goes to another planet, studies the planet a while, and then wanders over to squint at parts of its own wrecked spaceship. OK, so I don't have a flying car; I'm still living in the future.
Footnotes:
[1] I'd forgotten about this. For a while there, Opportunity was hogging the birthday glory; the project would wait until Opportunity's landing day to make a big deal out of the anniversary. But the first one was reversed: the big press conferences and such happened around Spirit's birthday. It wasn't until year 5 (2009) that they simply split the difference.
[2] Susan Kurtik hired me to work at JPL. I am endlessly grateful.
[3] True, except for the slanderous claim that I grew up.
So it's the beginning of Opportunity's second year on Mars, and the end of something else: namely, it's the end of our exploration of the heat shield. ("And there was much rejoicing ....")
I know, I said that last time. But this time, I really mean it. We planned the post-heat-shield drive, but there's one more thing they want us to do before we go. The MI images we got over the weekend looked great (I'm a genius!), but shooting them through the dust cover, as Erickson mandated to protect the instrument in case I screwed up, reduced the contrast. So the EDL team wants us to retake a few of them with the dust cover open. (To my surprise, Erickson agrees to this. I think that's to his surprise as well: "I said 'no' originally" he tells me, "but Squyres argued me around." Which is yet another surprise: the heat shield being primarily of engineering interest, the project has been generally unwilling to subject the rover to any risk over it -- for example, we can't use any of the instruments except the MI.) After that, we'll stow the IDD and drive away, as planned last week.
We're actually damn lucky we got anything at all. Last week, while building the sequences, there was a mix-up about which MI image sequences we were supposed to call. The first version of our IDD sequence used the wrong MI sequence IDs, but we redelivered a newer IDD sequence with the right MI sequence IDs in it. So far, nothing particularly unusual. But somehow, they managed to send the wrong version of the IDD sequence to the spacecraft! (We have software to warn about this, but they somehow managed to overlook the warning. Yeesh.) Happily, the "wrong" MI sequences were already on board, having been left over from some long-ago sol, so the spacecraft was happy -- it took images with a somewhat suboptimal exposure, but at least it took them.
But that was just dumb luck. It could easily have been otherwise: we could have moved the IDD to all the right places, and taken no pictures. Or, if the difference between the two IDD sequences had been something else, arbitrarily bad things could have happened. Lucky, lucky, lucky ....
At least thisol's sequencing is relatively easy. The drive's already in the bag, and the IDD stuff is just a subset of what we did over the weekend, so it's mostly a matter of copying and pasting. It doesn't take me very long to get it done. Which is great, because it leaves time for the Iowa Space Girl.
The Iowa Space Girl is Susan Kurtik's seven-year-old grandniece -- "she's bonkers about space," Susan says.[2] The Iowa Space Girl is also known as "Abigail," and I spend about half an hour showing her and her family around the MER area, letting her look through the 3-D glasses at Mars, letting her play with RSVP, and so on. Kids love RSVP, because it's like a video game -- which was the idea. "Scott got to grow up and get paid to write video games, and then he gets paid to play them," Susan says.[3] Abigail seems to like this idea.
Abigail seems like a great kid -- polite, smart, genuinely interested in space. But Steve Squyres is a big kid, too. On his way past he picks up a pair of the 3-D goggles and peers through them at the heat shield. "Gosh, what a weird-looking thing!" he exclaims. "A crashed spaceship on another planet!"
"Shame it's ours," I say.
He laughs. "Now that's a circumstance under which I'd be willing to use the APXS on it. APXS, MB, everything!"
[Next post: sol 387 (Opportunity sol 366), February 3.]
Courtesy NASA/JPL-Caltech. One of the MI images of Opportunity's heat shield. So, this robot goes to another planet, studies the planet a while, and then wanders over to squint at parts of its own wrecked spaceship. OK, so I don't have a flying car; I'm still living in the future.
Footnotes:
[1] I'd forgotten about this. For a while there, Opportunity was hogging the birthday glory; the project would wait until Opportunity's landing day to make a big deal out of the anniversary. But the first one was reversed: the big press conferences and such happened around Spirit's birthday. It wasn't until year 5 (2009) that they simply split the difference.
[2] Susan Kurtik hired me to work at JPL. I am endlessly grateful.
[3] True, except for the slanderous claim that I grew up.
2010-01-23
Opportunity Sol 356 (Spirit Sol 376)
It's Leo's last sol on MER; after today, he moves on to MSL. He picked a heck of a sol for his last: we're in on a Saturday, for one thing; for another, we're planning three sols today.
So we've got a lot of work to do, but we can't get started on it. The auto-generated terrain meshes are useless; they used the horizon mask, which clips off any features above a certain height. Normally, this is a sensible thing to do, which is why it's the default for the automated process -- the stereo correlation will occasionally be confused by some distant feature and try to place it in the mesh near the rover and a meter or so off the ground, and usually we just clip that junk out.
But in this case, the heat shield shoulder piece projects above the limit. Naturally, the horizon mask clips it off just below the area we're interested in. I came in last night to pick a few spots in the imagery that are possible candidates for our MI survey, but we can't do the real work until the meshes come along.
So right off the bat, we're delayed by an hour. If I believed in omens, I'd call this a bad one.
Not only is it Leo's last sol, it's also Ray Arvidson's birthday. And Jim Erickson's.
At least we've got some free time to celebrate ....
But when the meshes show up, I'm able to get to work. We had an aggressive plan for MIing a long strip, but the three-dimensional view shows that this will be impossible: we want to avoid touching the material, and we're constrained by a fluffy piece on the left and a jagged finger on the right. The entire reachable range is maybe 5cm, much less than we'd planned for. What's more, the surface we're trying to MI is barely visible from our current position: the HAZCAMs almost can't see it, since it lies mostly along their line of sight, and in the NAVCAM we took to compensate for that (since we knew it might happen), the strip they want to image is obscured by the upthrust fluffy piece.
One way to respond to this situation is to take more images, closer together. This helps compensate for the uncertainty we're facing, and the total number of images (and corresponding downlink volume) will still be less than we'd planned for when we thought we could get a large range.
To add to the pressure, everyone really wants these MIs to turn out well. Once we get them, we're done at the heat shield and can move on to the etched terrain. We've been at the heat shield about a month, and except for our SpongeBob observations, it's been a purely engineering-oriented endeavor -- no real science at all. So the scientists are champing at the bit to move on, and the management team wants to cut loose as well.
Luckily for us, we have an ace up our sleeve. An ace named Eric Baumgartner -- Andy asked him to come in today (on a Saturday!) and help out as needed. Eric suggests a different direction for the stacks, one that might track the surface of the strip better, but ends up mostly doing analysis. Which is just as good as far as I'm concerned: if Eric says the sequence is okay, you can bet your house on it. And he says it's okay.
When I'm done, I spend some time looking over the sequence. It's about a hundred commands or so, only moderately complex by IDD-sequence standards. I find myself thinking that for all the trouble I had building the damn thing, it ought to be longer.
Meanwhile, Cooper's been working on the drive. We're going to wait until we see the MI results, and if they look good, we'll uplink the drive sequence and be gone as of sol 358. Otherwise, Cooper's just wasting his time -- yet another reason I really want to get my part right.[1]
Despite a mishap that requires Cooper to rewrite the entire drive sequence, and despite all the time I take, we're not the ones holding up the process thisol. For some reason, it's just one of those days on Mars -- both Spirit and Opportunity have a series of random ground software problems that delay the process, seemingly endlessly, and they're still holding things up when I have to leave for an radio interview.
Lucky me; since Cooper's staying, I can leave. Leo's not so lucky -- he's got nobody to backstop him, and he'd promised his wife he'd leave by 6:30 so she could take him out to dinner.
"How much do divorces cost these days?" he sighs.[2]
[Next post: sol 378 (Opportunity sol 358), January 25.]
[1] This overstates the case a little: Cooper's drive sequence could have simply been used on a later sol. It still would have meant he was spending his Saturday doing work that could have been done on a normal weekday, but it wouldn't have been altogether wasted.
[2] Comfortably into six figures. Don't ask me how I know.
2010-01-21
Opportunity Sol 355 (Spirit Sol 374)
Leo Bister asks, "Who's driving thisol?"
Frank and I point to Khaled.
Leo cocks an eye at Khaled and grins wickedly. "Oh, good -- I'll be sure to ask lots of questions ...."
While I was gone, they IDDd the heck out of SpongeBob, finding pretty much what the scientists expected: it's a meteorite. Amazing stuff, and I'm sorry I missed it.
But we're back to the heat shield now. Yestersol's drive brought Opportunity back to an approach position, and thisol we're just bumping 70cm or so to get the piece of interest into the IDD work volume. Khaled's going to do the actual drive, but we have a lot of work to do to decide precisely where it should take us.
To do this, we have to study previous images of this wacky object -- all taken from different perspectives, with different cameras, under different lighting conditions -- and figure out where the strip of TPS material is now, with respect to the rover. It's while doing this that I get really, really annoyed about something.
One of the EDL team members who's been working on this with us, shows me an image from our previous position. He runs his finger along part of it, a part that looks like a bumpy railroad track -- "This is the part we want to MI, right here."
The part he's pointing to is exactly the part I worked out a way to get to the last time we were here, right before he claimed he'd need images at an up-angle -- the angle we couldn't get to from that position, which led to our temporarily leaving the heat shield.
But the part he's running his fingers along is visible from a NAVCAM image, an image where we were looking down at the part.
Which means the part is facing up.
Which means shooting at an up-angle is useless -- we have to shoot at a cross-angle, or down.
Which is what I had before.
MotherFUCKer.
Making matters even worse, our reapproach angle is constrained -- we won't be able to get back to the spot we were in before. Our new position will likely be worse.
I need John Wright to come by and say, "This is so cool." But he's off thisol.
Ah, fuck it. We'll do our best. And tomorrow, we'll see how good that was.
[Next post: sol 376 (Opportunity sol 356), January 23.]
2010-01-12
Opportunity Sol 345 (Spirit Sol 366)
When we start planning, we don't have the downlink. "So we don't know whether Khaled broke the rover?" I ask Frank. He looks at me, fakes a worried face, and shakes his head no.
Of course, when the data arrives, it transpires that Khaled has done a perfect job; the rover's right where we wanted it.
We're ready to reapproach. But in the middle of the discussion, the science team decides to completely change the plan. Again.
The issue is the long MLK holiday weekend: if we start the heat shield work now, we'll have one sol of IDD work and mostly waste the vehicle's time over the weekend. But if we drive to SpongeBob now, we'll have a ton of IDD work to do there throughout the weekend, using the vehicle much better. So we're going to just drive to SpongeBob thisol, and return to the heat shield on a future sol.
Despite Khaled's success on his first drive, Frank and I decide to sequence this one. Frank slaps together a candidate drive, then goes off to hack RSVP while I modify and refine it. And a nice job I do of it, too: we reapproach part of the way to the heat shield, taking PANCAM images of the part we'll eventually want to come back and IDD, then we're off to SpongeBob in a long, lazy "Z"-drive that avoids nearby debris scraps.
The scientists' interest in SpongeBob is easy to understand: remote sensing suggests it's an iron meteorite! Like our own spacecraft, it likely fell from outer space to the surface of Mars. The weird part is that it's so damn close to our heat shield, just meters away. Either these meteorites are all over Mars, or this is one damn freaky coincidence.
Or, as I jokingly suggest, we hit it during the cruise stage and knocked it into Mars ourself. If that had really happened, of course, there'd be a more recent, hence more prominent, crater around it. The idea might be highly implausible, but it's fun.
I enjoy working on thisol's drive, despite having the usual RP-1 experience of continual interruptions and plan changes. "You sure you want this job?" I tease Khaled.
He answers wryly, "You haven't done data management."
[Next post: sol 374 (Opportunity sol 355), January 21.]

Courtesy NASA/JPL-Caltech. Our next destination, SpongeBob, is in the upper left of this image. The science team called "SpongeBob" by another name, "Heat Shield Rock," apparently because they couldn't think of anything more boring. But it'll always be "SpongeBob" (or sometimes "SpongeRock") to me.
Of course, when the data arrives, it transpires that Khaled has done a perfect job; the rover's right where we wanted it.
We're ready to reapproach. But in the middle of the discussion, the science team decides to completely change the plan. Again.
The issue is the long MLK holiday weekend: if we start the heat shield work now, we'll have one sol of IDD work and mostly waste the vehicle's time over the weekend. But if we drive to SpongeBob now, we'll have a ton of IDD work to do there throughout the weekend, using the vehicle much better. So we're going to just drive to SpongeBob thisol, and return to the heat shield on a future sol.
Despite Khaled's success on his first drive, Frank and I decide to sequence this one. Frank slaps together a candidate drive, then goes off to hack RSVP while I modify and refine it. And a nice job I do of it, too: we reapproach part of the way to the heat shield, taking PANCAM images of the part we'll eventually want to come back and IDD, then we're off to SpongeBob in a long, lazy "Z"-drive that avoids nearby debris scraps.
The scientists' interest in SpongeBob is easy to understand: remote sensing suggests it's an iron meteorite! Like our own spacecraft, it likely fell from outer space to the surface of Mars. The weird part is that it's so damn close to our heat shield, just meters away. Either these meteorites are all over Mars, or this is one damn freaky coincidence.
Or, as I jokingly suggest, we hit it during the cruise stage and knocked it into Mars ourself. If that had really happened, of course, there'd be a more recent, hence more prominent, crater around it. The idea might be highly implausible, but it's fun.
I enjoy working on thisol's drive, despite having the usual RP-1 experience of continual interruptions and plan changes. "You sure you want this job?" I tease Khaled.
He answers wryly, "You haven't done data management."
[Next post: sol 374 (Opportunity sol 355), January 21.]
Courtesy NASA/JPL-Caltech. Our next destination, SpongeBob, is in the upper left of this image. The science team called "SpongeBob" by another name, "Heat Shield Rock," apparently because they couldn't think of anything more boring. But it'll always be "SpongeBob" (or sometimes "SpongeRock") to me.
2010-01-11
Opportunity Sol 344 (Spirit Sol 365)
The plan for thisol is a touch-and-go: we'll MI the shoulder piece of the heat shield, then drive to SpongeBob. Reaching the exact spot the TPS team wants to see is going to be tricky -- indeed, it initially looks impossible -- but I keep hacking away at it, and together Frank and I figure out a way. Then we show it to the main guy, Ben.
Ben isn't satisfied. He wants the pictures from a different angle.
Okay, then. The angle he wants can't be reached from our current position; the arm interferes with itself when trying to get into the right spot. So after all that work, we blow off the IDD stuff for the day, and change the drive as well. Instead, we'll have to do a two-sol "reapproach" -- stow the IDD, then back off from the heat shield and, nextersol, come back in to a spot where we can scratch the TPS team's itch. ("Well, today went from really hard to really easy," Frank mutters.)
While I was immersed in the IDD stuff we ended up scrapping, Frank suggested we let Khaled[1] handle the drive, which sounded fine to me. I start to regret acquiescing when we decide that the IDD "work" thisol will amount to little more than a stow. But as it turns out, the IDD work is more interesting than expected. We just need to retract the MB from the magnets and stow, but with the heat shield in the way, our maneuvering room is tightly constrained; the usual procedure would whack the arm into the heat shield. So my strategy is, roughly, to reverse the moves that they used to get the IDD up there in the first place, so that we're going through known-working positions on the way out. In doing this, I discover that we had less than a millimeter of clearance at one point! Yikes.
With that stuff done, we turn to discussing nextersol's drive, the reapproach part. One of our decisions is to take images of the underside of the broken-off piece during the reapproach. When we were right next to the heat shield, we were at the right distance but the wrong angle to see the area we were interested in. So as we drive in, we'll take images from one or two standoff positions, trading resolution for viewing angle. If it turns out the underside's shape will keep us from being able to place the IDD at all, we'll know we needn't bother to deploy. Then it occurs to us that we could have taken those pictures on this drive, as we backed away; that would have potentially saved us a sol. By the time we think of this, it's too late to fix it, so we just shrug collectively. We'll get the pictures tomorrow, and that's that.
The exciting discovery of the day is that Khaled is on a terrorist watch list. Well, not our Khaled Ali, but there is a Khaled Ali on the list, so our guy gets special treatment every time he flies. He found out about this when airline security personnel started asking him if he has a tattoo. He does -- on his back; the terrorist suspect has one on his left arm.
"Next time they ask you if you have a tattoo, you should say, 'Not on my left arm,'" I suggest. "Blow their minds."
"I don't mess with those guys," he says.
[1] Khaled Ali, whom we'd recently started training as a rover driver.
2010-01-06
Opportunity Sol 339 (Spirit Sol 360)
"Thank God the spacecraft is smarter than we are," Art says wryly. Our manual data product deletes failed yesterday, so Opportunity deleted some for us to keep flash from getting too full. It was so busy doing this that the sun-find timed out, which kept Opportunity from updating its attitude knowledge. So Opportunity decided it didn't know its current attitude, which causes it to mark itself unsafe for driving. Luckily, this problem was discovered last night, and Opportunity's already been manually reset to a better state of attitude knowledge.
But the autodeletes are a problem. You'll remember a few days back, when Jim Bell wanted to take some sky-flat images to help calibrate the PANCAM data, and he and Justin Maki got into a rather acrimonious argument about it? Well, the sky flats weren't taken that sol, but they were taken on a later sol. But they hadn't been downloaded yet. And guess what the autodelete logic just deleted?
So they're going to have to take those again.
Justin has something else to worry about today -- namely, me. There's something that's been annoying me through much of the extended mission. During the nominal mission, we built the post-drive NAVCAM sequences from scratch each sol; as a result, we could assign a sequence ID up front and worry about the pointing later, when we had the drive done and knew what we needed. But nowadays we're trying to use a "sequence library," which means we try to pick an already-built sequence. We still have to choose a sequence ID up front, but since sequences in the library are identified by sequence ID, this implies that we're choosing the post-drive imaging before the drive is built.
Obviously, this is screwed up. That decision was driven by another screwed-up decision made somewhere else, and, well, long story short, it's not going to get fixed today. Most of the time it doesn't matter; we image such a wide area that we have plenty of room for error. (Which is another gripe: why are we so wasteful? Maybe if we weren't so routinely wasteful, we wouldn't have needed autodelete, which killed the sky flats and ... ah, never mind.) But on this sol, we narrowed the post-drive imaging to save on downlink, and we're going to have to play with the drive to ensure we get onto the right approach vector for our final approach to the heat shield.
This combination of things -- an incompletely specified drive and a narrow field of view for the post-drive imaging -- is exactly the case where the sequence library approach is at its worst. Justin originally chooses a post-drive NAVCAM centered at 90 degrees, but after talking with the TPS folks, it becomes clear we should shoot for a very different orientation to the heat shield. (Which is bad news for Jeff, too, in a way. He couldn't sleep, so he came in early and built the drive. Now I have to rebuild it. That's fun for me, but he must feel he wasted a bit of his time.) So he has to redeliver with a new mosaic centered around 72 degrees.
Then I start looking at the situation more carefully in RSVP. Turns out that the new azimuth is fine, but I'm not as sanguine about the elevation. RSVP shows the NAVCAM pointing as being marginal -- we should get the whole heat shield, but about a third of the image is above the heat shield, and it's doubtful we'll see its bottom edge. Since the bottom edge is nearer to what we want to IDD, and more importantly what we'd smack the rover into in the event of a misjudgment, I'd feel safer about lowering the pointing a notch.
Justin argues against this change, and his is not a judgment to dismiss lightly. It's not just that he doesn't want to re-redeliver; he's sure we're going to image the heat shield whether we lower the elevation or not, and if we keep it the way it is, we're more likely to get distant features (namely, our own tracks) in the distance, which makes the images look cooler when MIPL converts them to overhead mosaics.
Justin knows this stuff like the back of his hand; it's hard to escape the feeling that arguing with him about it makes me a jerk. But in the end I decide to ask him to change it. Getting the tracks in the NAVCAMs would be cool, but getting the entire heat shield is critical. If we're aimed lower than necessary, then we'll just image more of the terrain leading up to the heat shield, which is perfectly fine with me; whatever we can't see well in the front HAZCAM view of this area, we'll pick up in the NAVCAMs.
So Justin redelivers again.
Note to self: if Justin was right and I was wrong, apologize profusely.
Second note to self: prepare to apologize profusely.
Worse yet, most of this work might be moot -- or, at least, delayed. Despite the space cleared out by autodelete, we won't have enough room in flash to do the entire planned sol unless we get confirmation of some additional manual deletes that were uplinked at the last second last night. The plan for the sol is, first, to drive up next to the heat shield, about 2m away, and take a whole bunch of pictures. Then we back off and drive around to its west side, where we take some more pictures. (Assuming this all goes well, we'll be able to approach to IDD range on the following sol.) But if we don't have room in flash, we won't be able to take all the pictures, which means we'll cut the sol in half. The work won't be entirely lost, but we'll have to defer most of it by a sol.
So we go ahead, hoping for the best. And our optimism is rewarded when Roger Klemm strolls into the room with a big grin on his face. "The deletes succeeded," he announces. "We have 361 megabits available." So we're good to go.
And "go" we do. If anything, we go too fast. When we finish the CAM, Emily complains about exactly that. "That went too fast," she said. "Did we miss something?" She's serious enough about it to bring up her checklist and go over it. But we didn't miss anything. Apparently, we're just getting better at this. Maybe we're smarter than Art thinks.
[Next post: sol 365 (Opportunity sol 344), January 11.]
2010-01-05
Opportunity Sol 338 (Spirit Sol 359)
I'm nice and early, arriving in the SOWG room maybe ten minutes early for the 08:30 start time. I'm feeling pretty good.
"You can go home," Charles Budney says.
"What?"
"You can go home." He shrugs. "Or stay late."
"What happened?"
"It's a fuck-up -- no data until 15:20. We're treating it as a restricted sol."
Which means no driving, no IDDing. That blows our schedule out of the water. We were supposed to do our final approach to the heat shield thisol, but now we'll have to put that off for a day. "I'll stay late."
"Tell Art."
I do that, but Art shakes his head. "You're one of many."
That's what I expected. "Gotcha," I say, "but I'm casting my vote. I'm happy to stay late and get this done. After all, I hate to blow off a million-dollar sol."
"Well, in Euros, it's only a couple hundred thousand."
So that doesn't happen. I don't know what caused the delay, except that it resulted from some kind of DSN problem, and it's expected to continue for the near future.
Before leaving, I sign a 50-Tolarjev note -- Slovenian currency. This is something like 29 cents, in US currency. (What did thisol cost in Slovenian Tolarjev? I don't want to think about it.) This kind of thing happens now and then; a space fan from somewhere in the world sends in something for the ops team to sign. I'm always happy to do this, as indeed is most of the ops team. We're just engineers with unusually cool jobs, but it's nice when somebody makes you feel like a rock star.
Justin's the only one who refuses to sign it. "Isn't that illegal?" he frets. "I'm sure I'd be breaking some international money law, or something."
Justin is a nice guy, and a heck of a bright guy; I like him a lot. But for the love of God, Justin! Interpol is not going to drag you off to some UN dungeon for scrawling your name on a Slovenian banknote!
Subscribe to:
Posts (Atom)

 Posts


